R01 • Current development
Wheel-Bipedal Balancing Robot
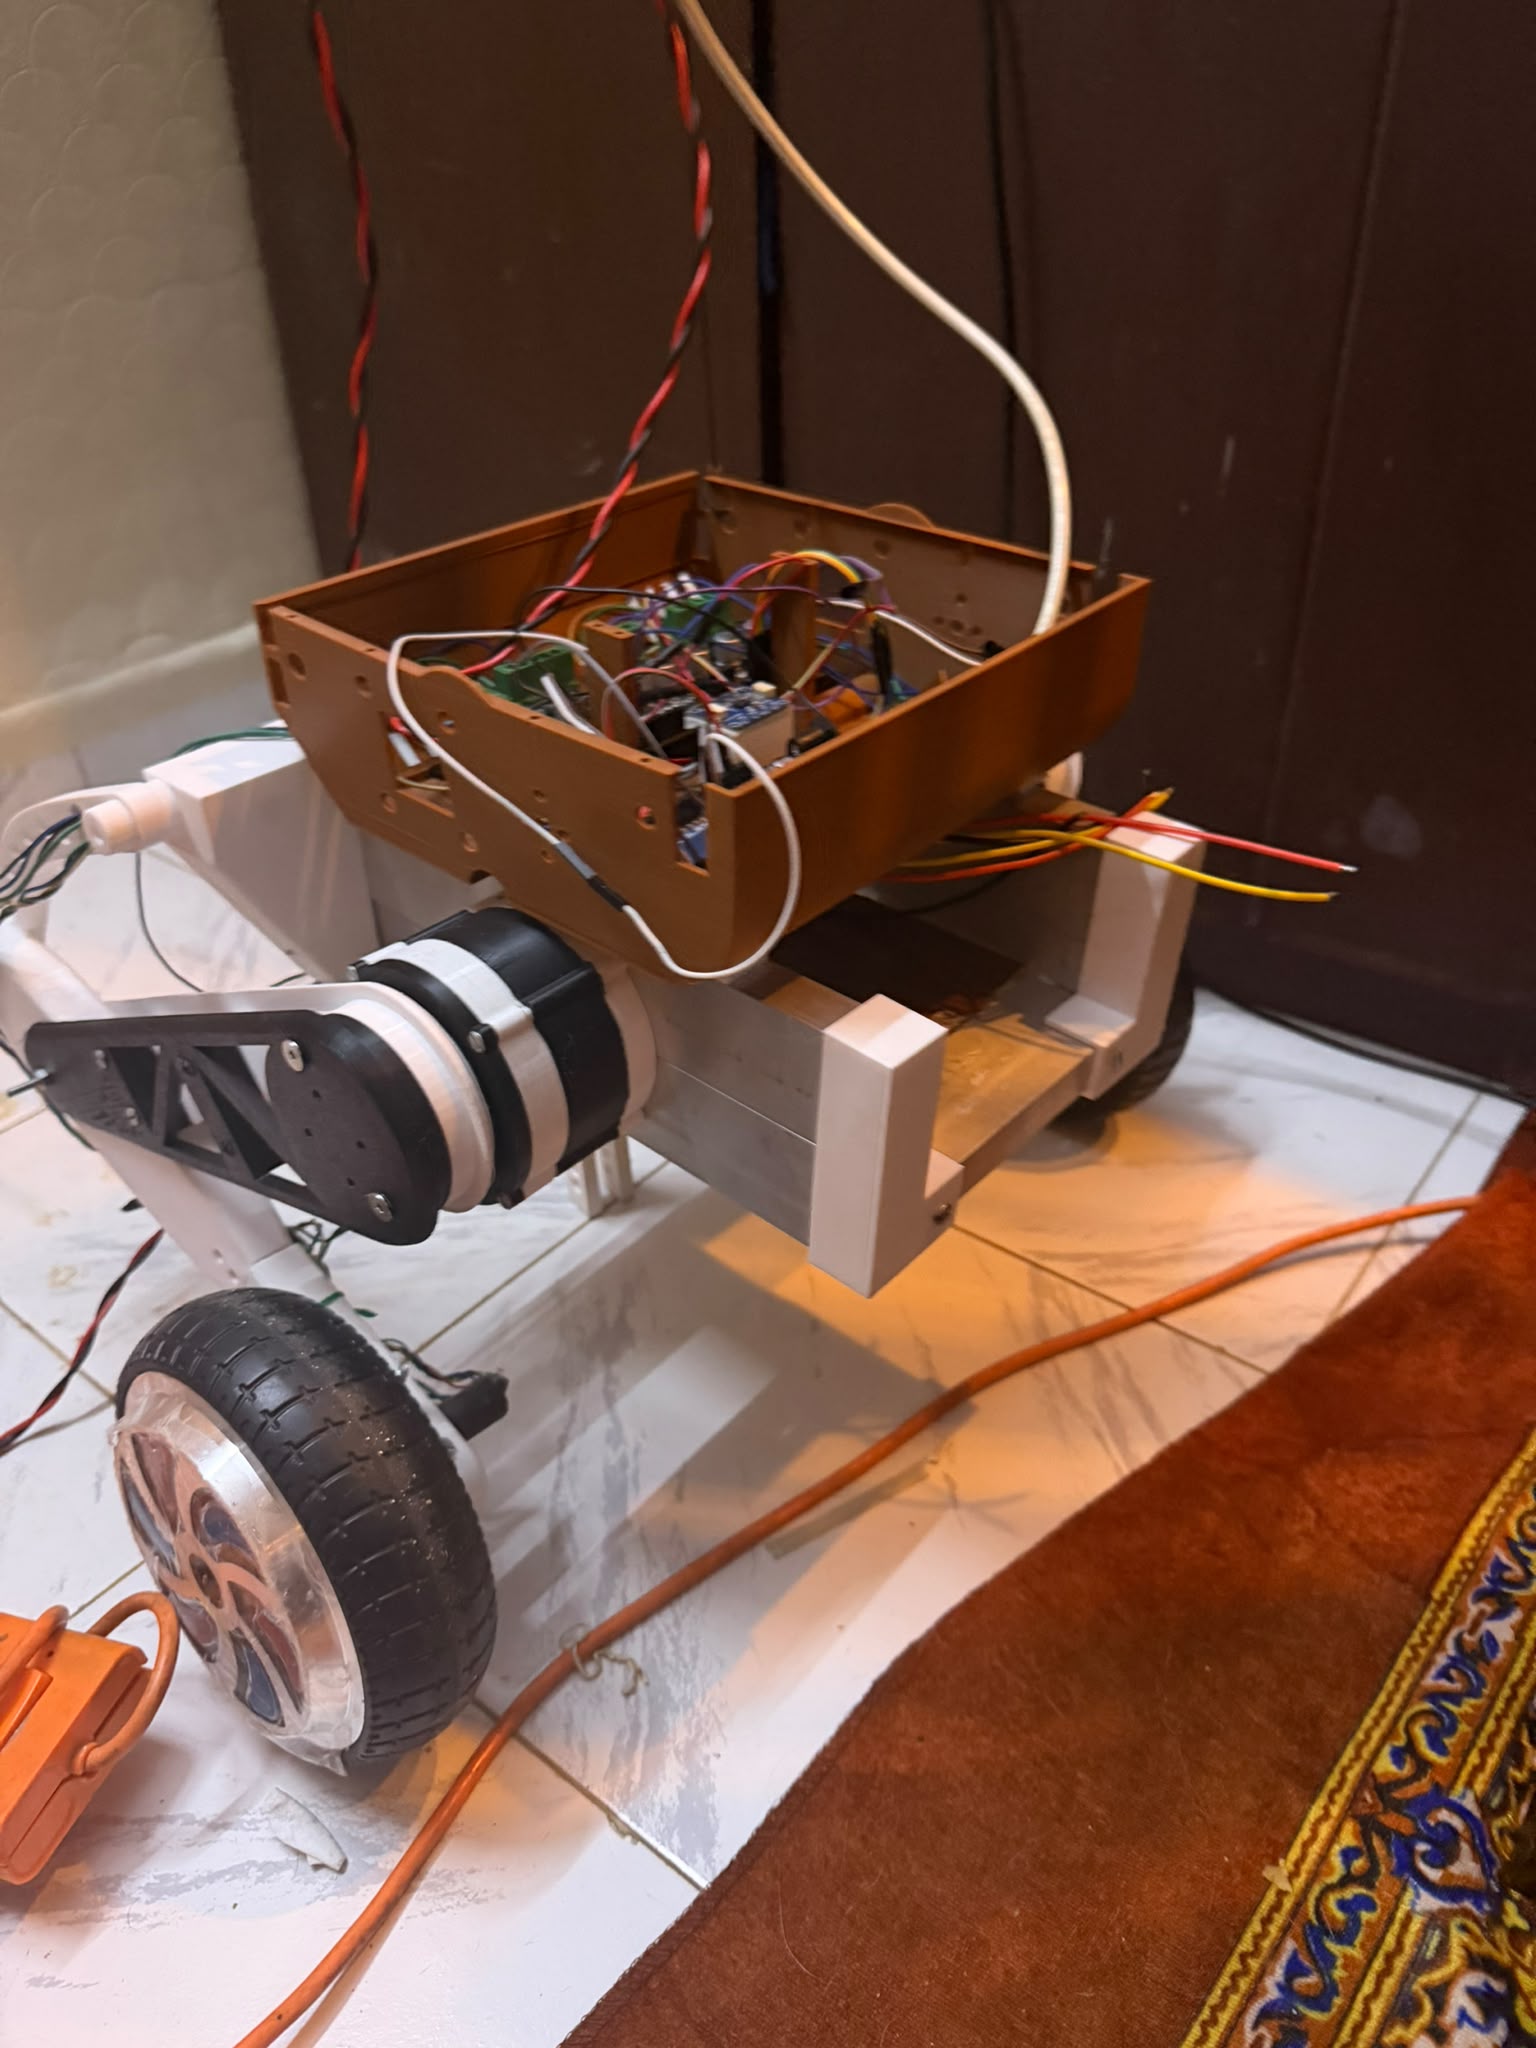
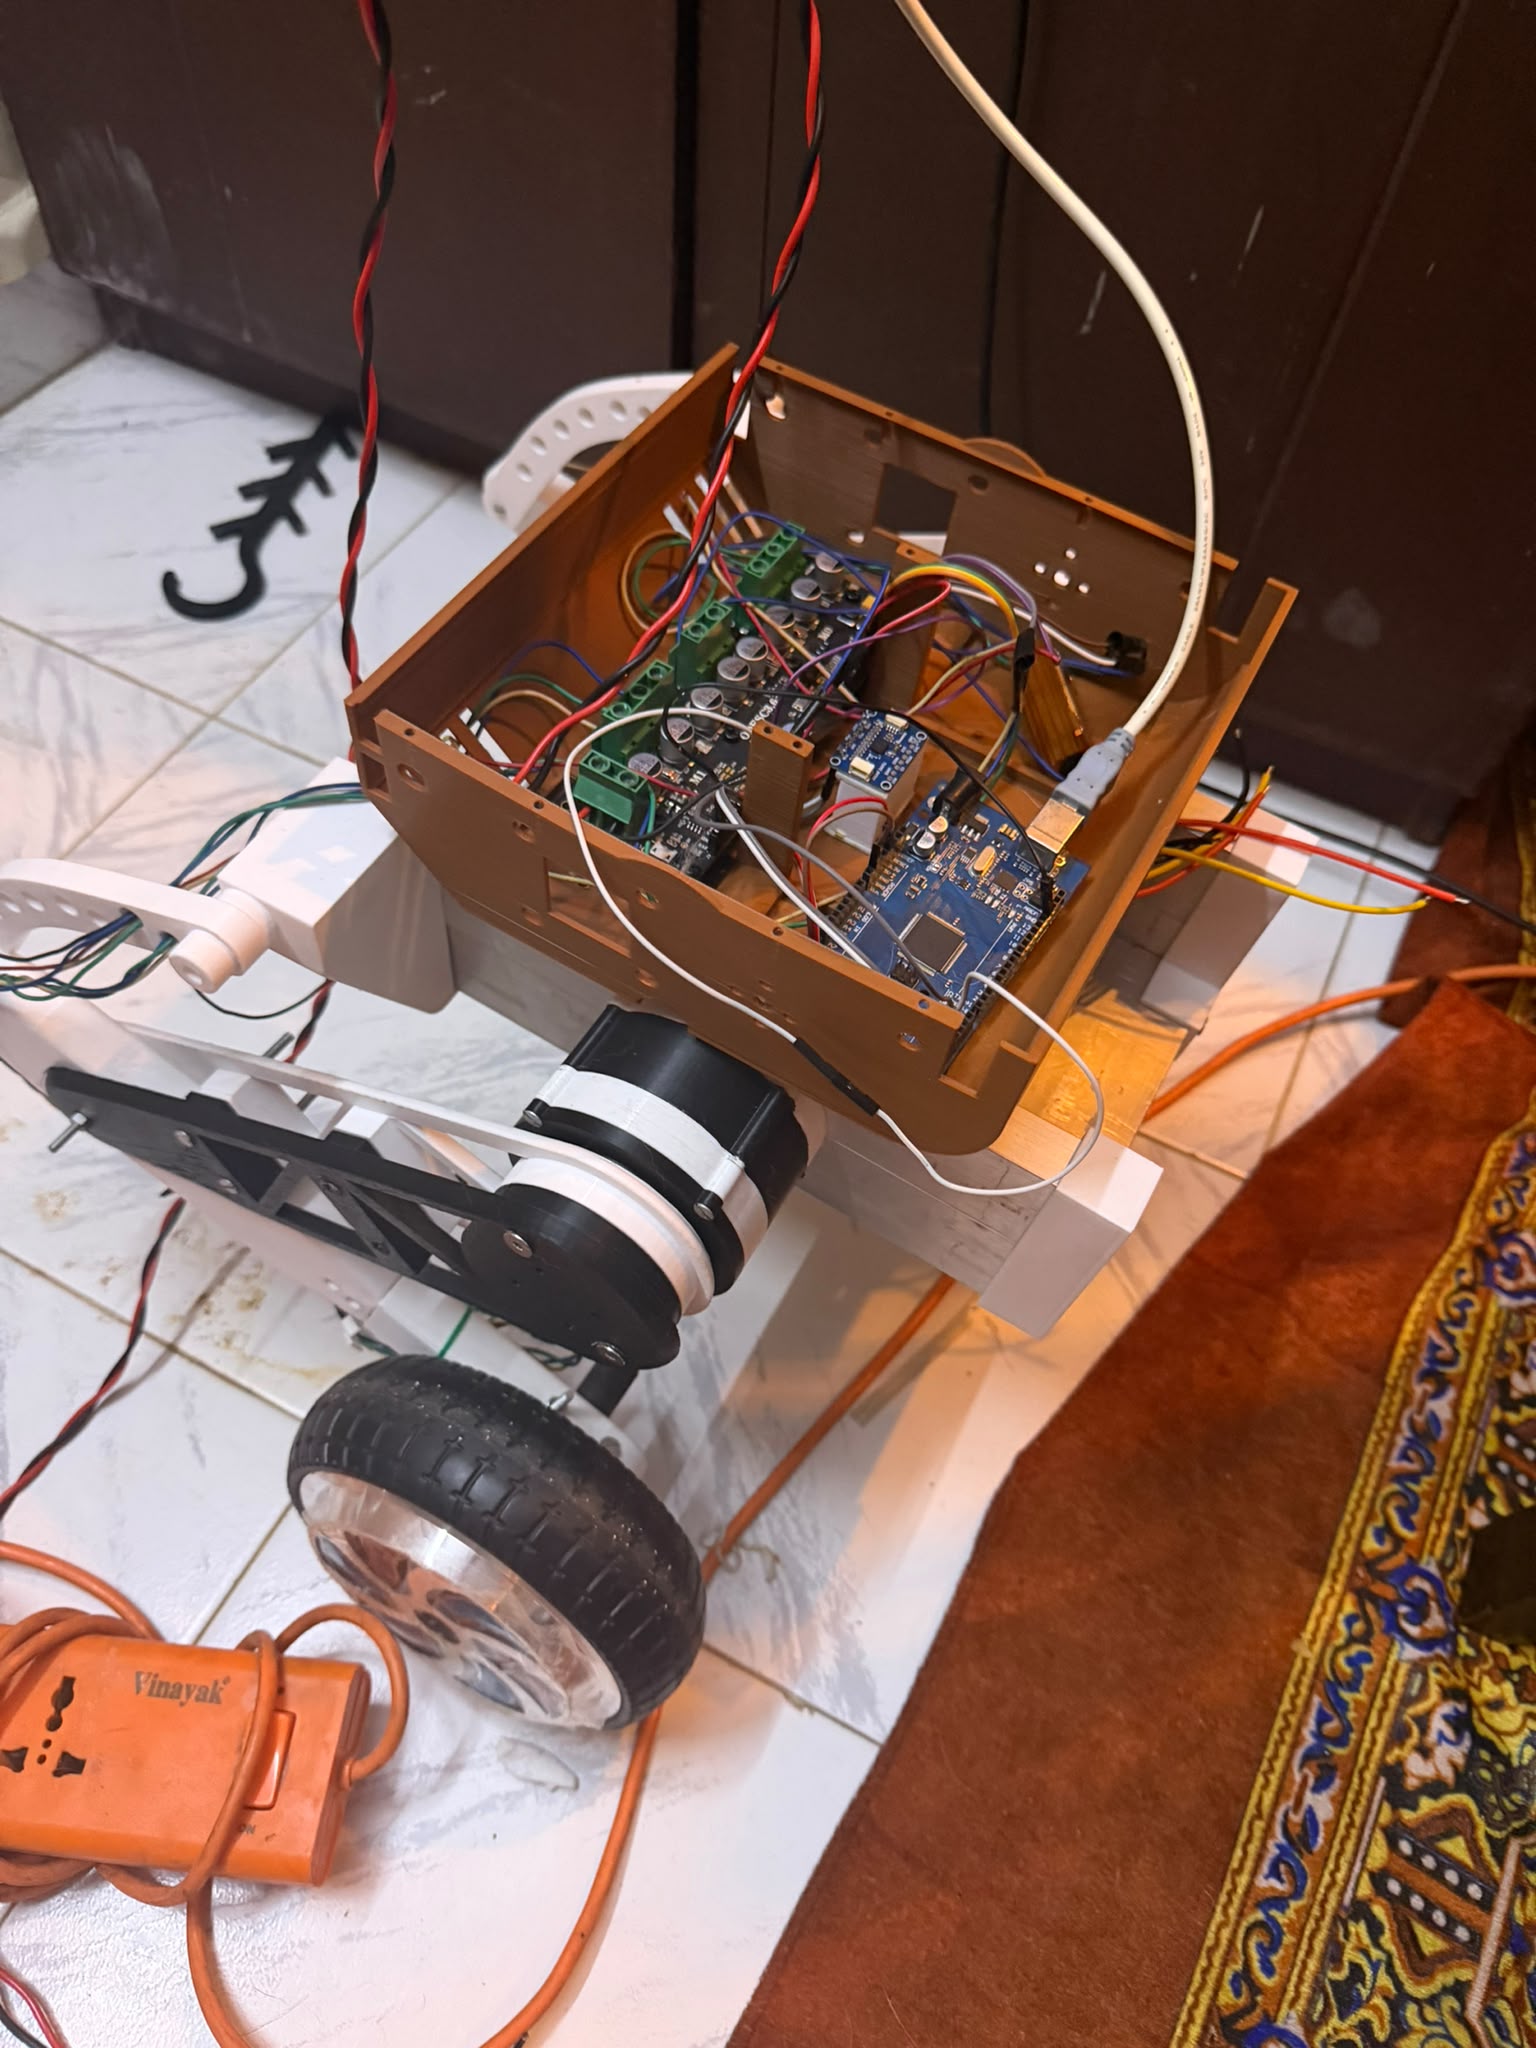
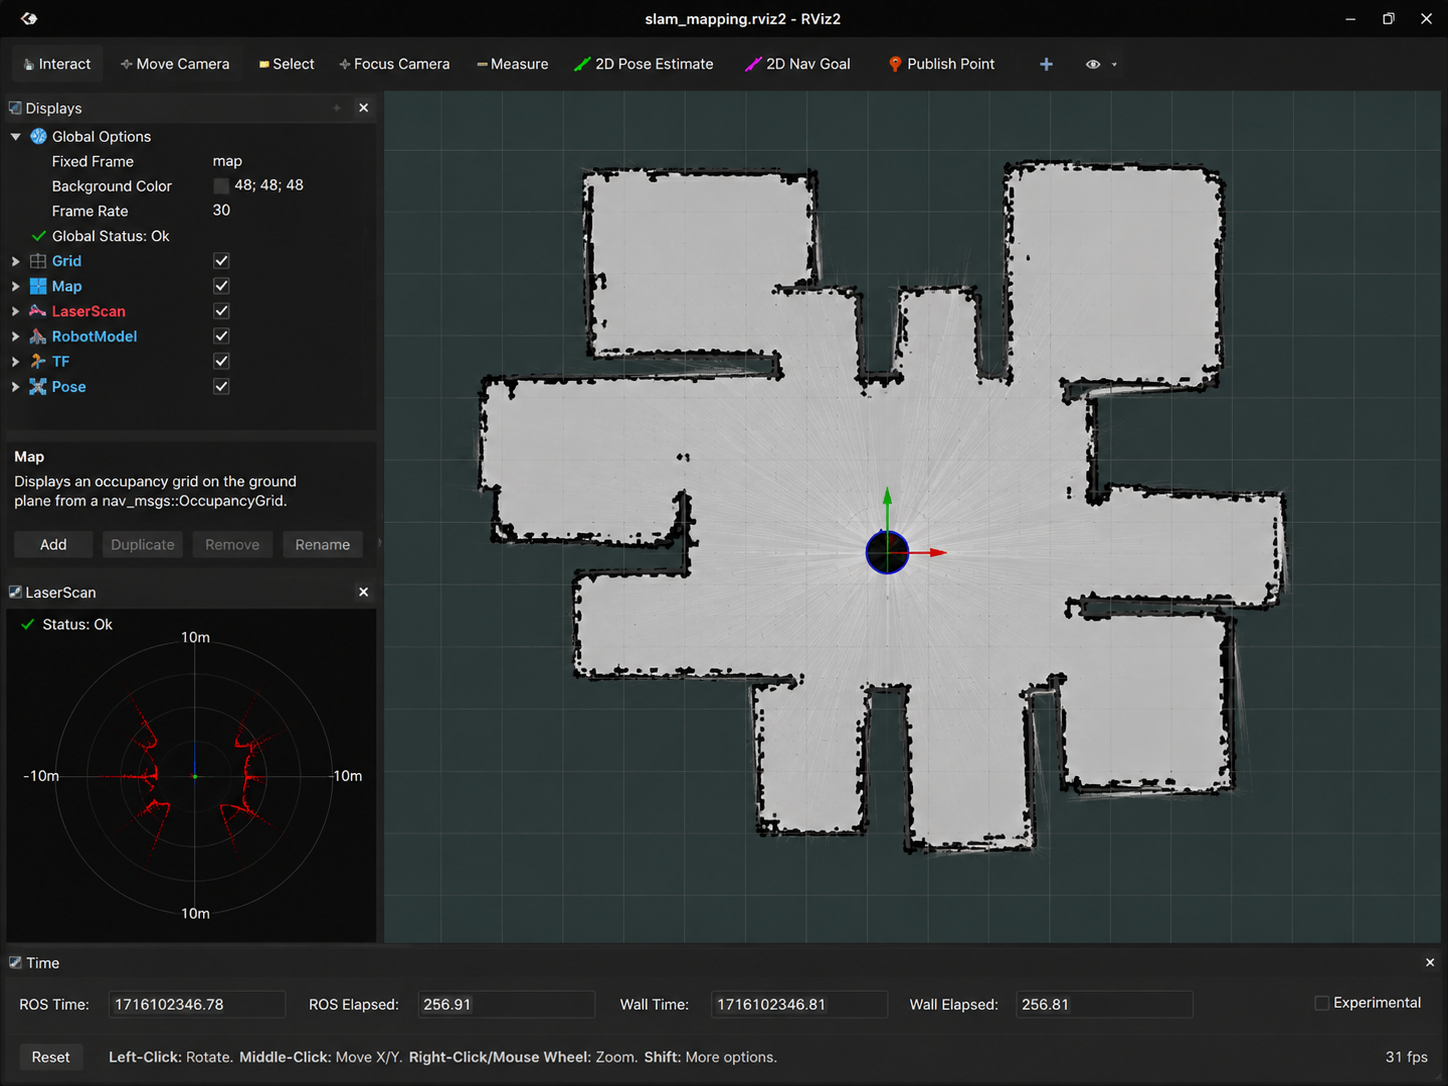
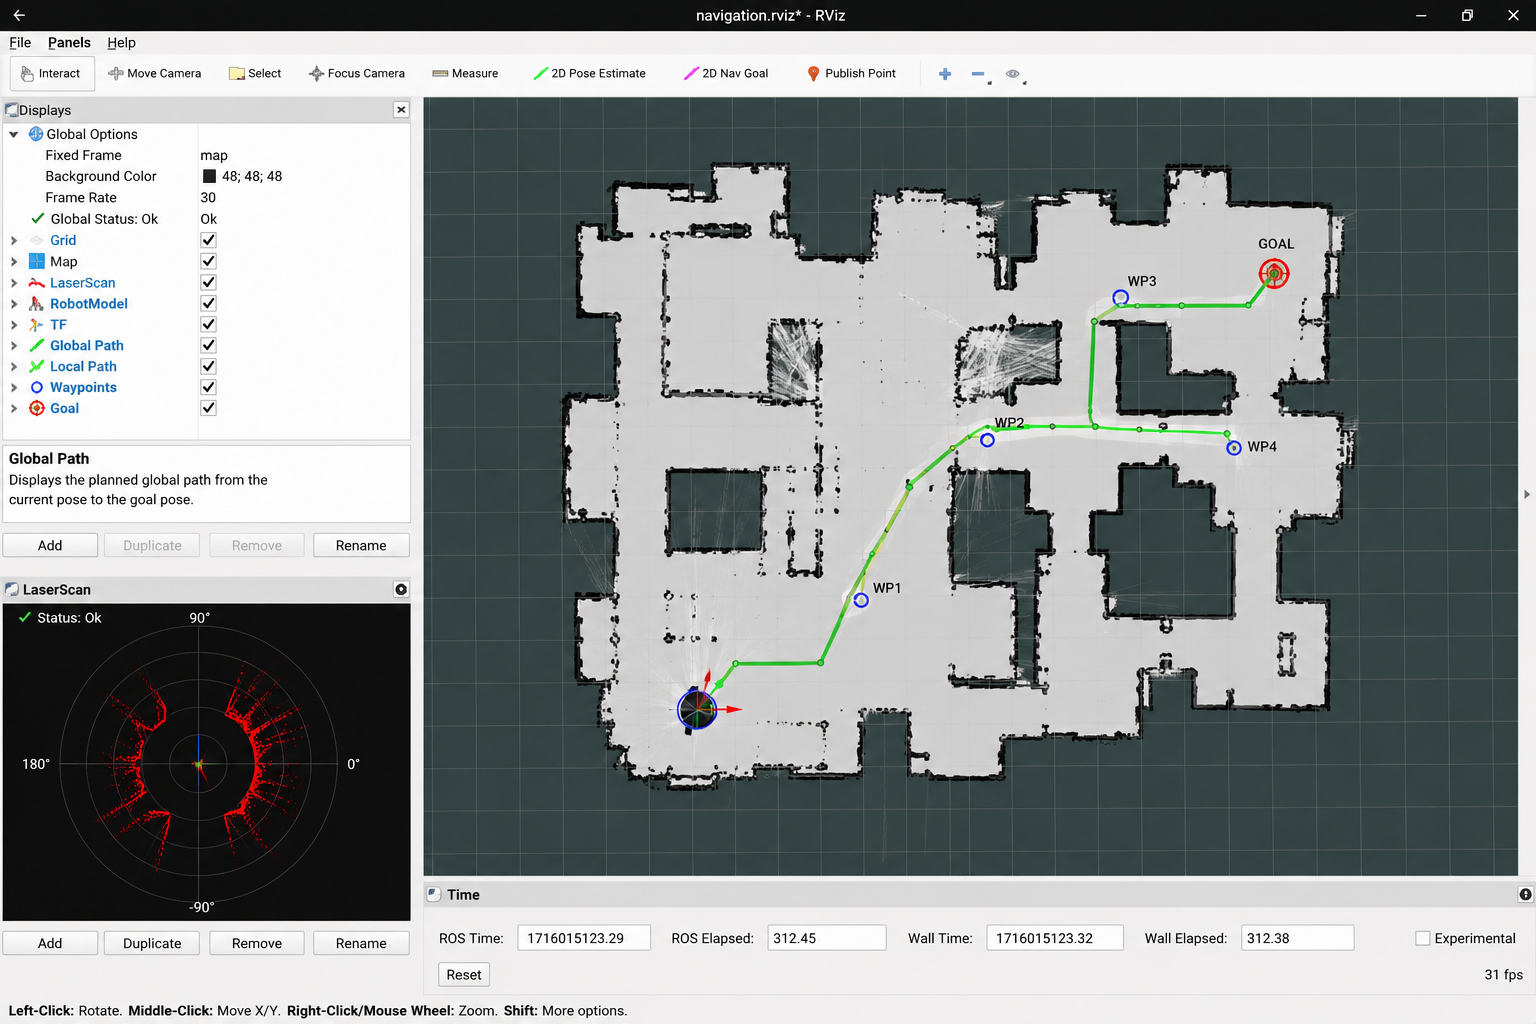
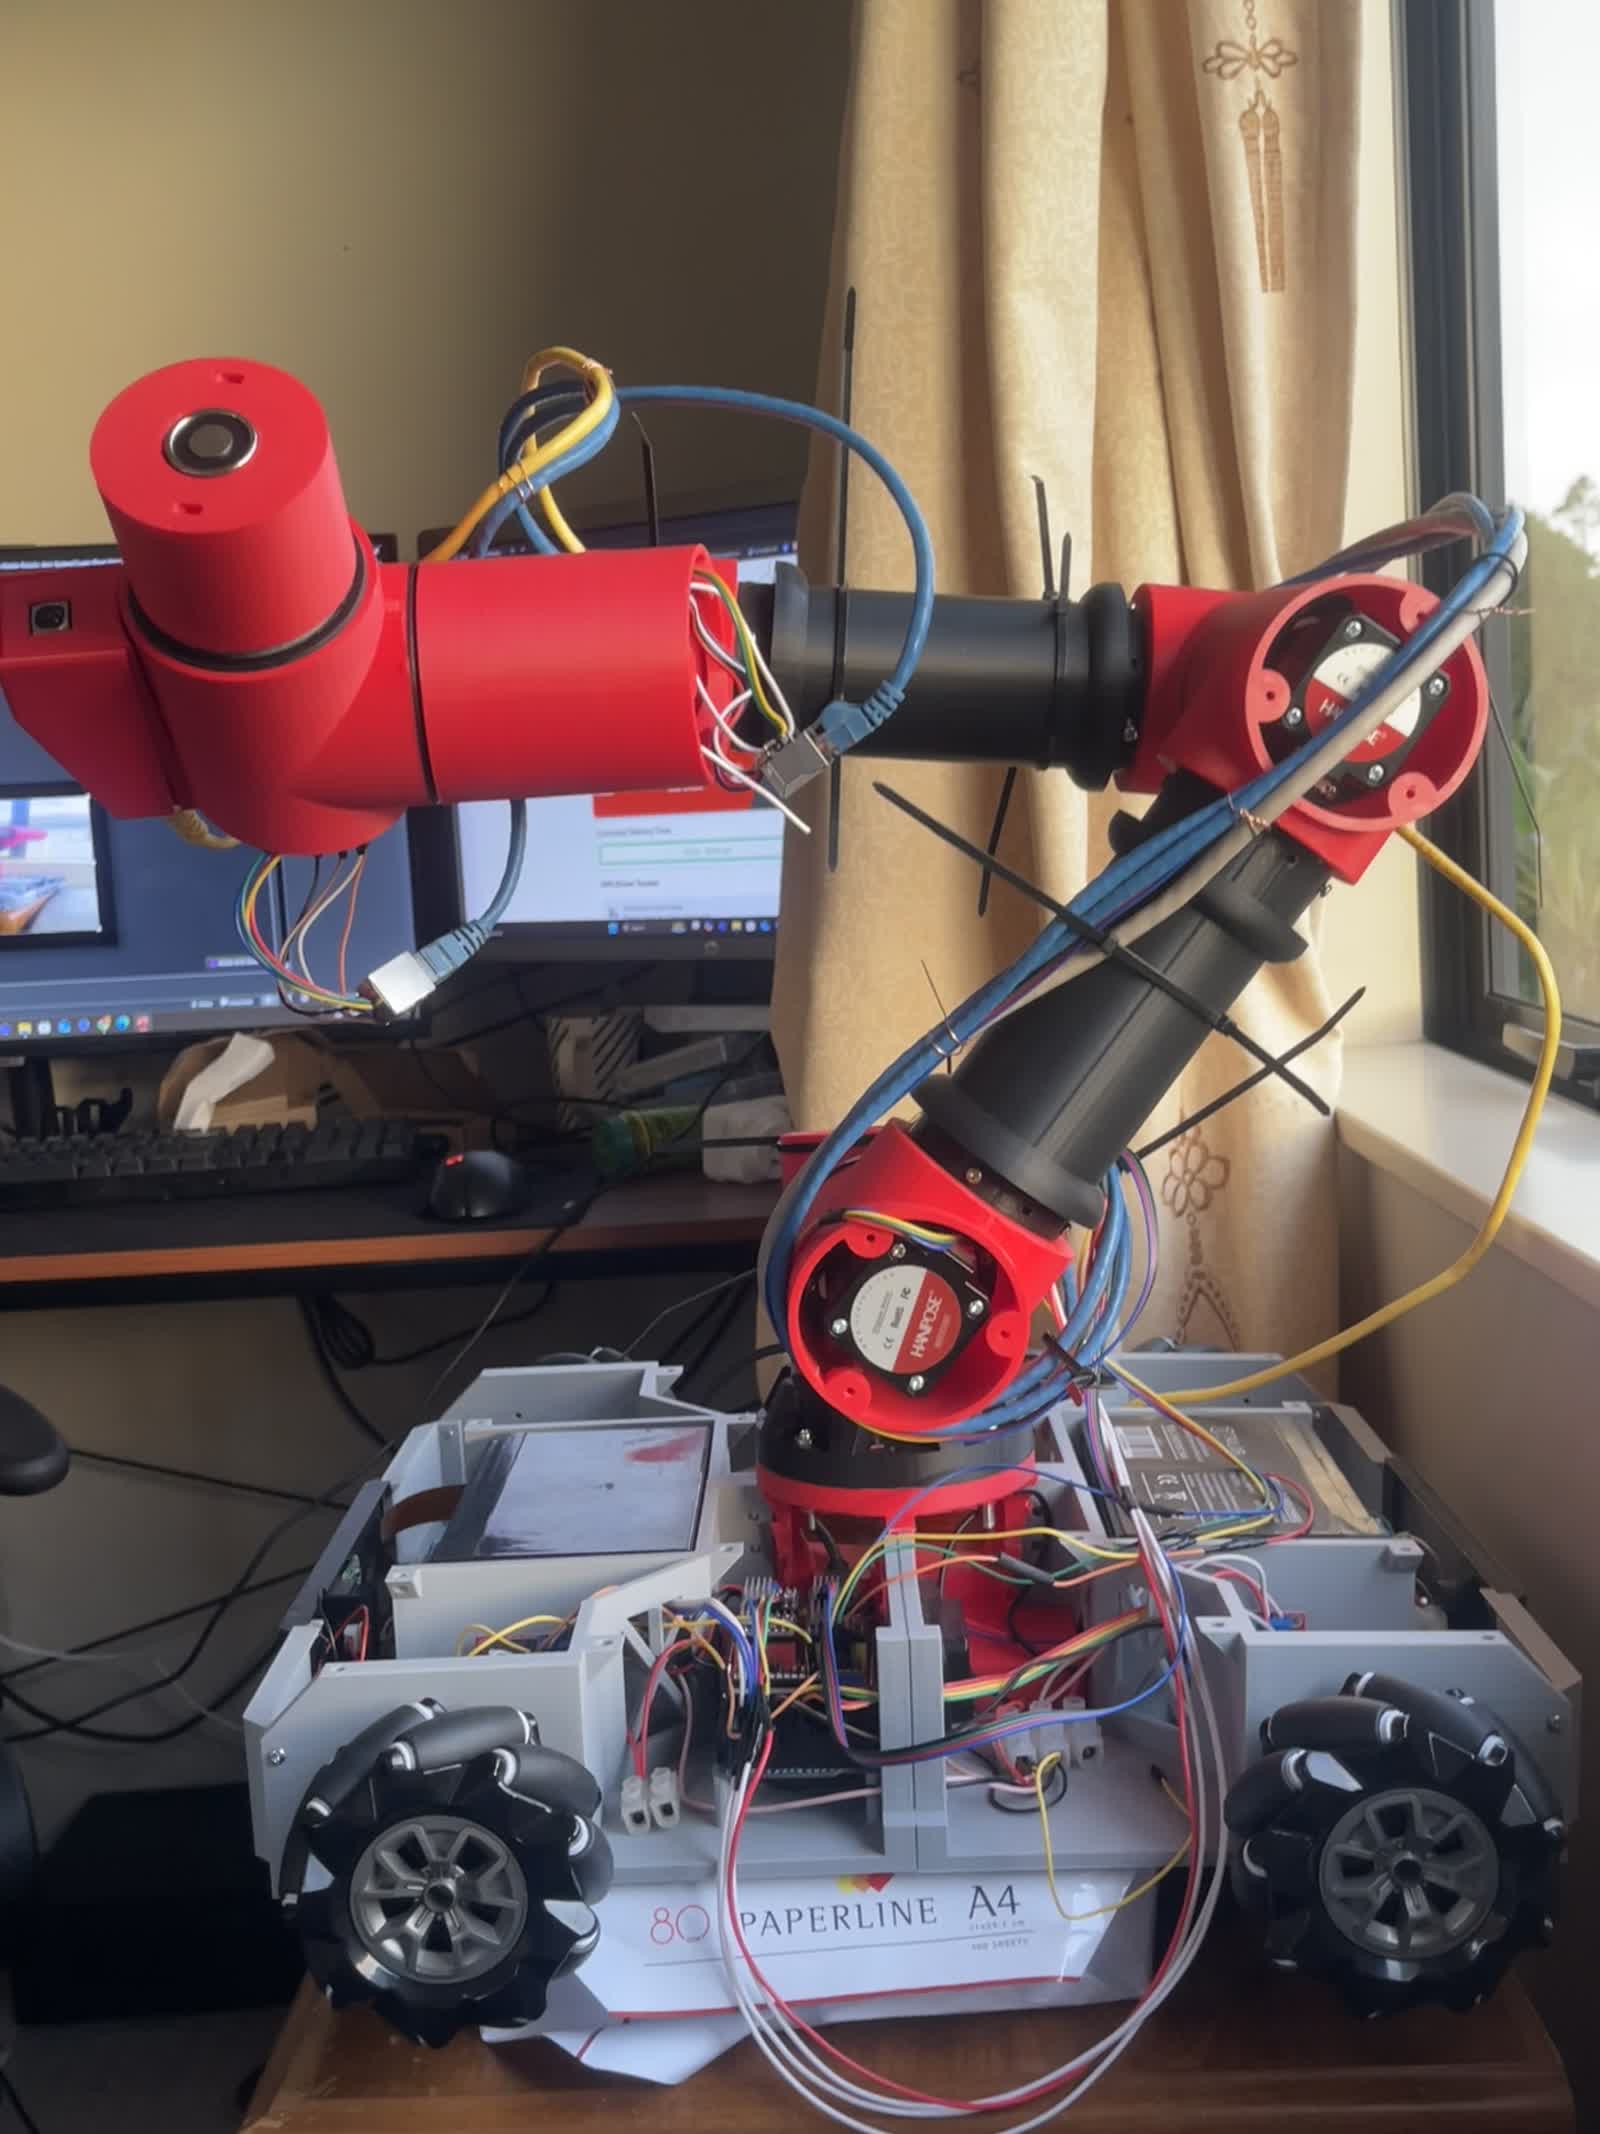
This Project began as a two-wheel self-balancing platform and is being developed into a wheel-bipedal robot. The current Control system combines hoverboard hub motors, ODrive Controller, BNO086 orientation feedback and an Arduino Mega.
Control theory
The Balancing controller continuously compares the robot's measured body angle with its upright setpoint. The proportional term reacts to angle error, the derivative term damps angular motion, and the integral term can compensate for persistent bias. The resulting controller output is converted into left and right wheel torque.
Web control and tuning
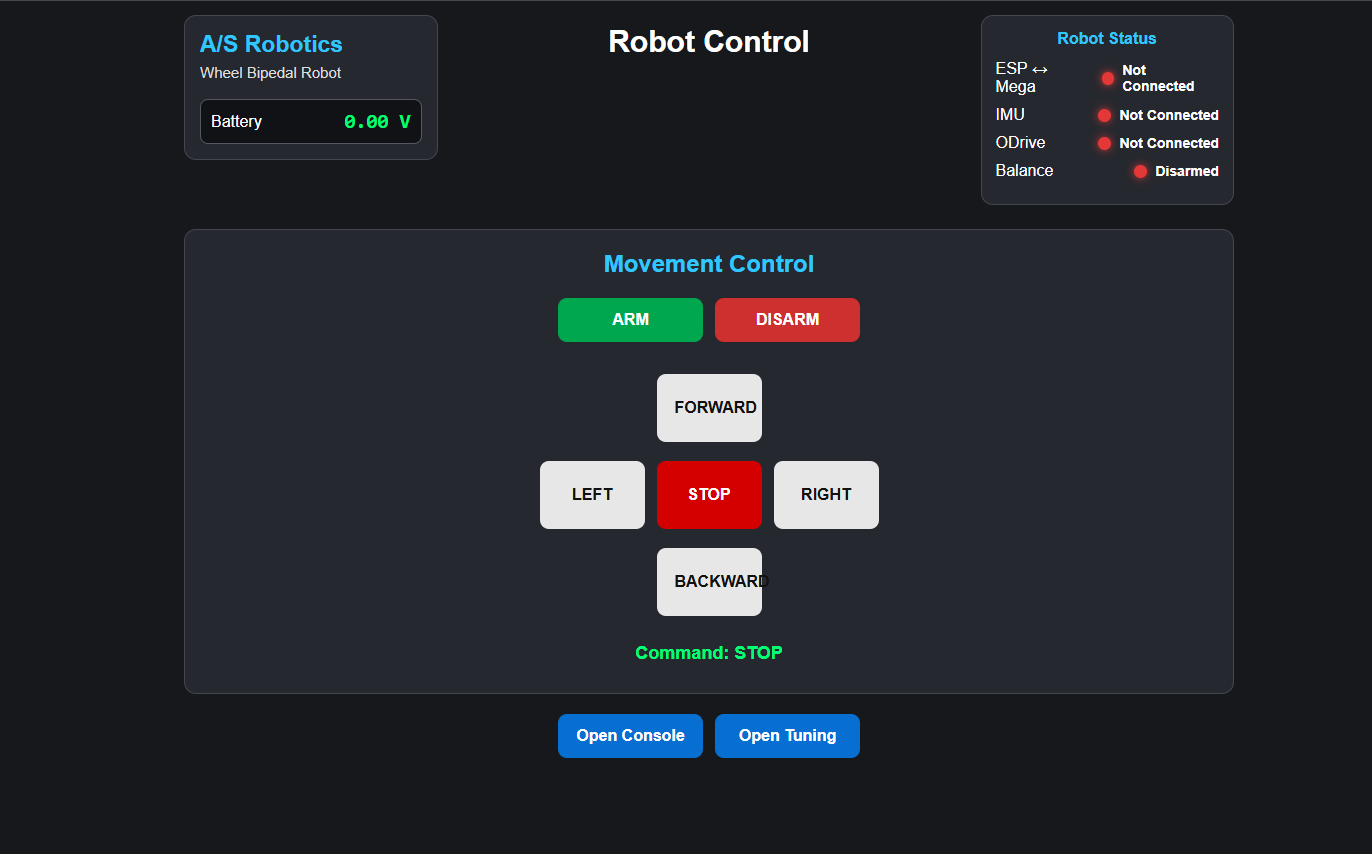
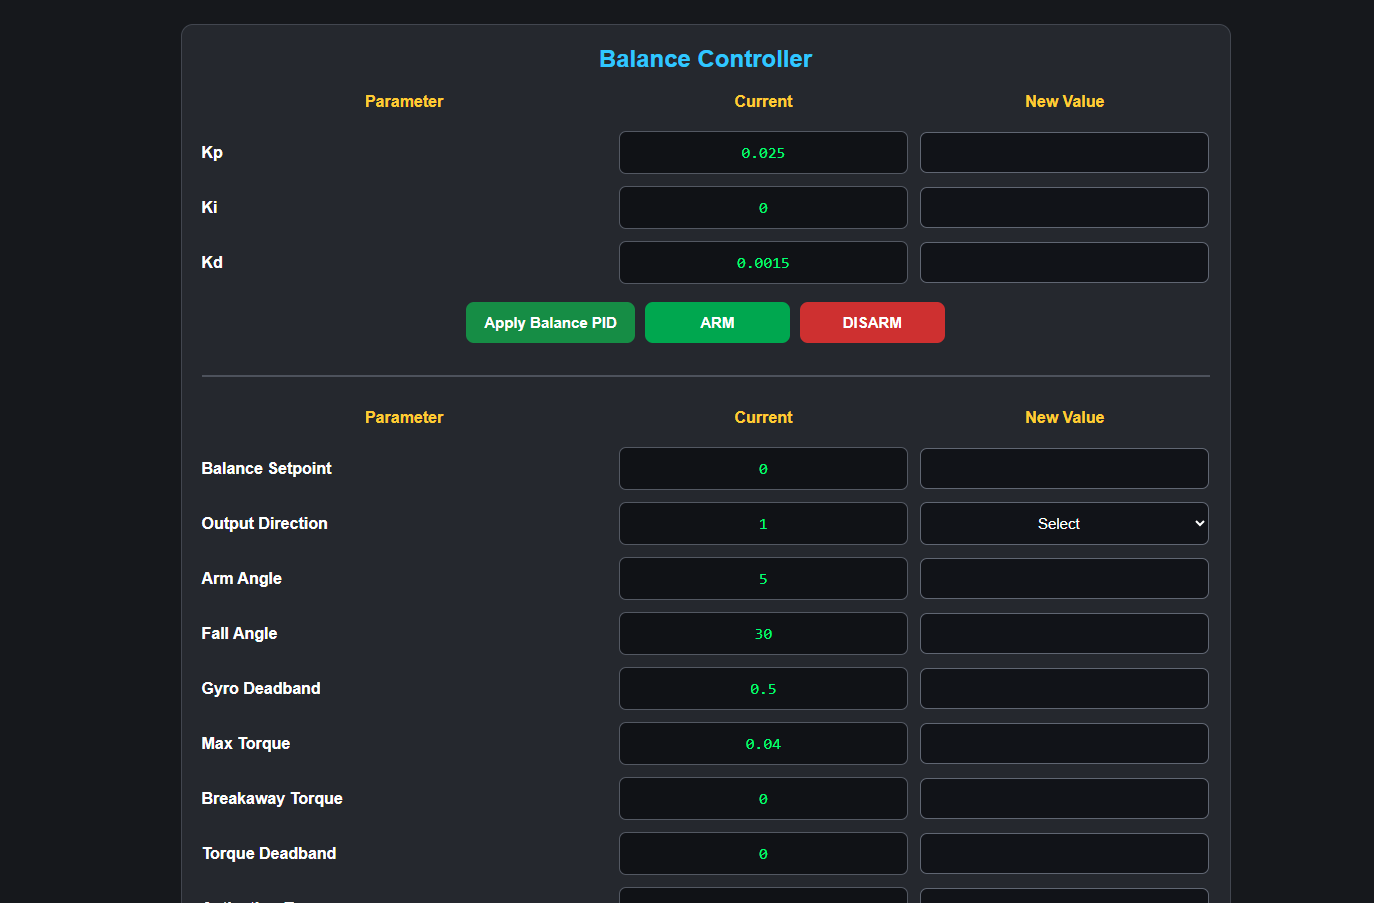
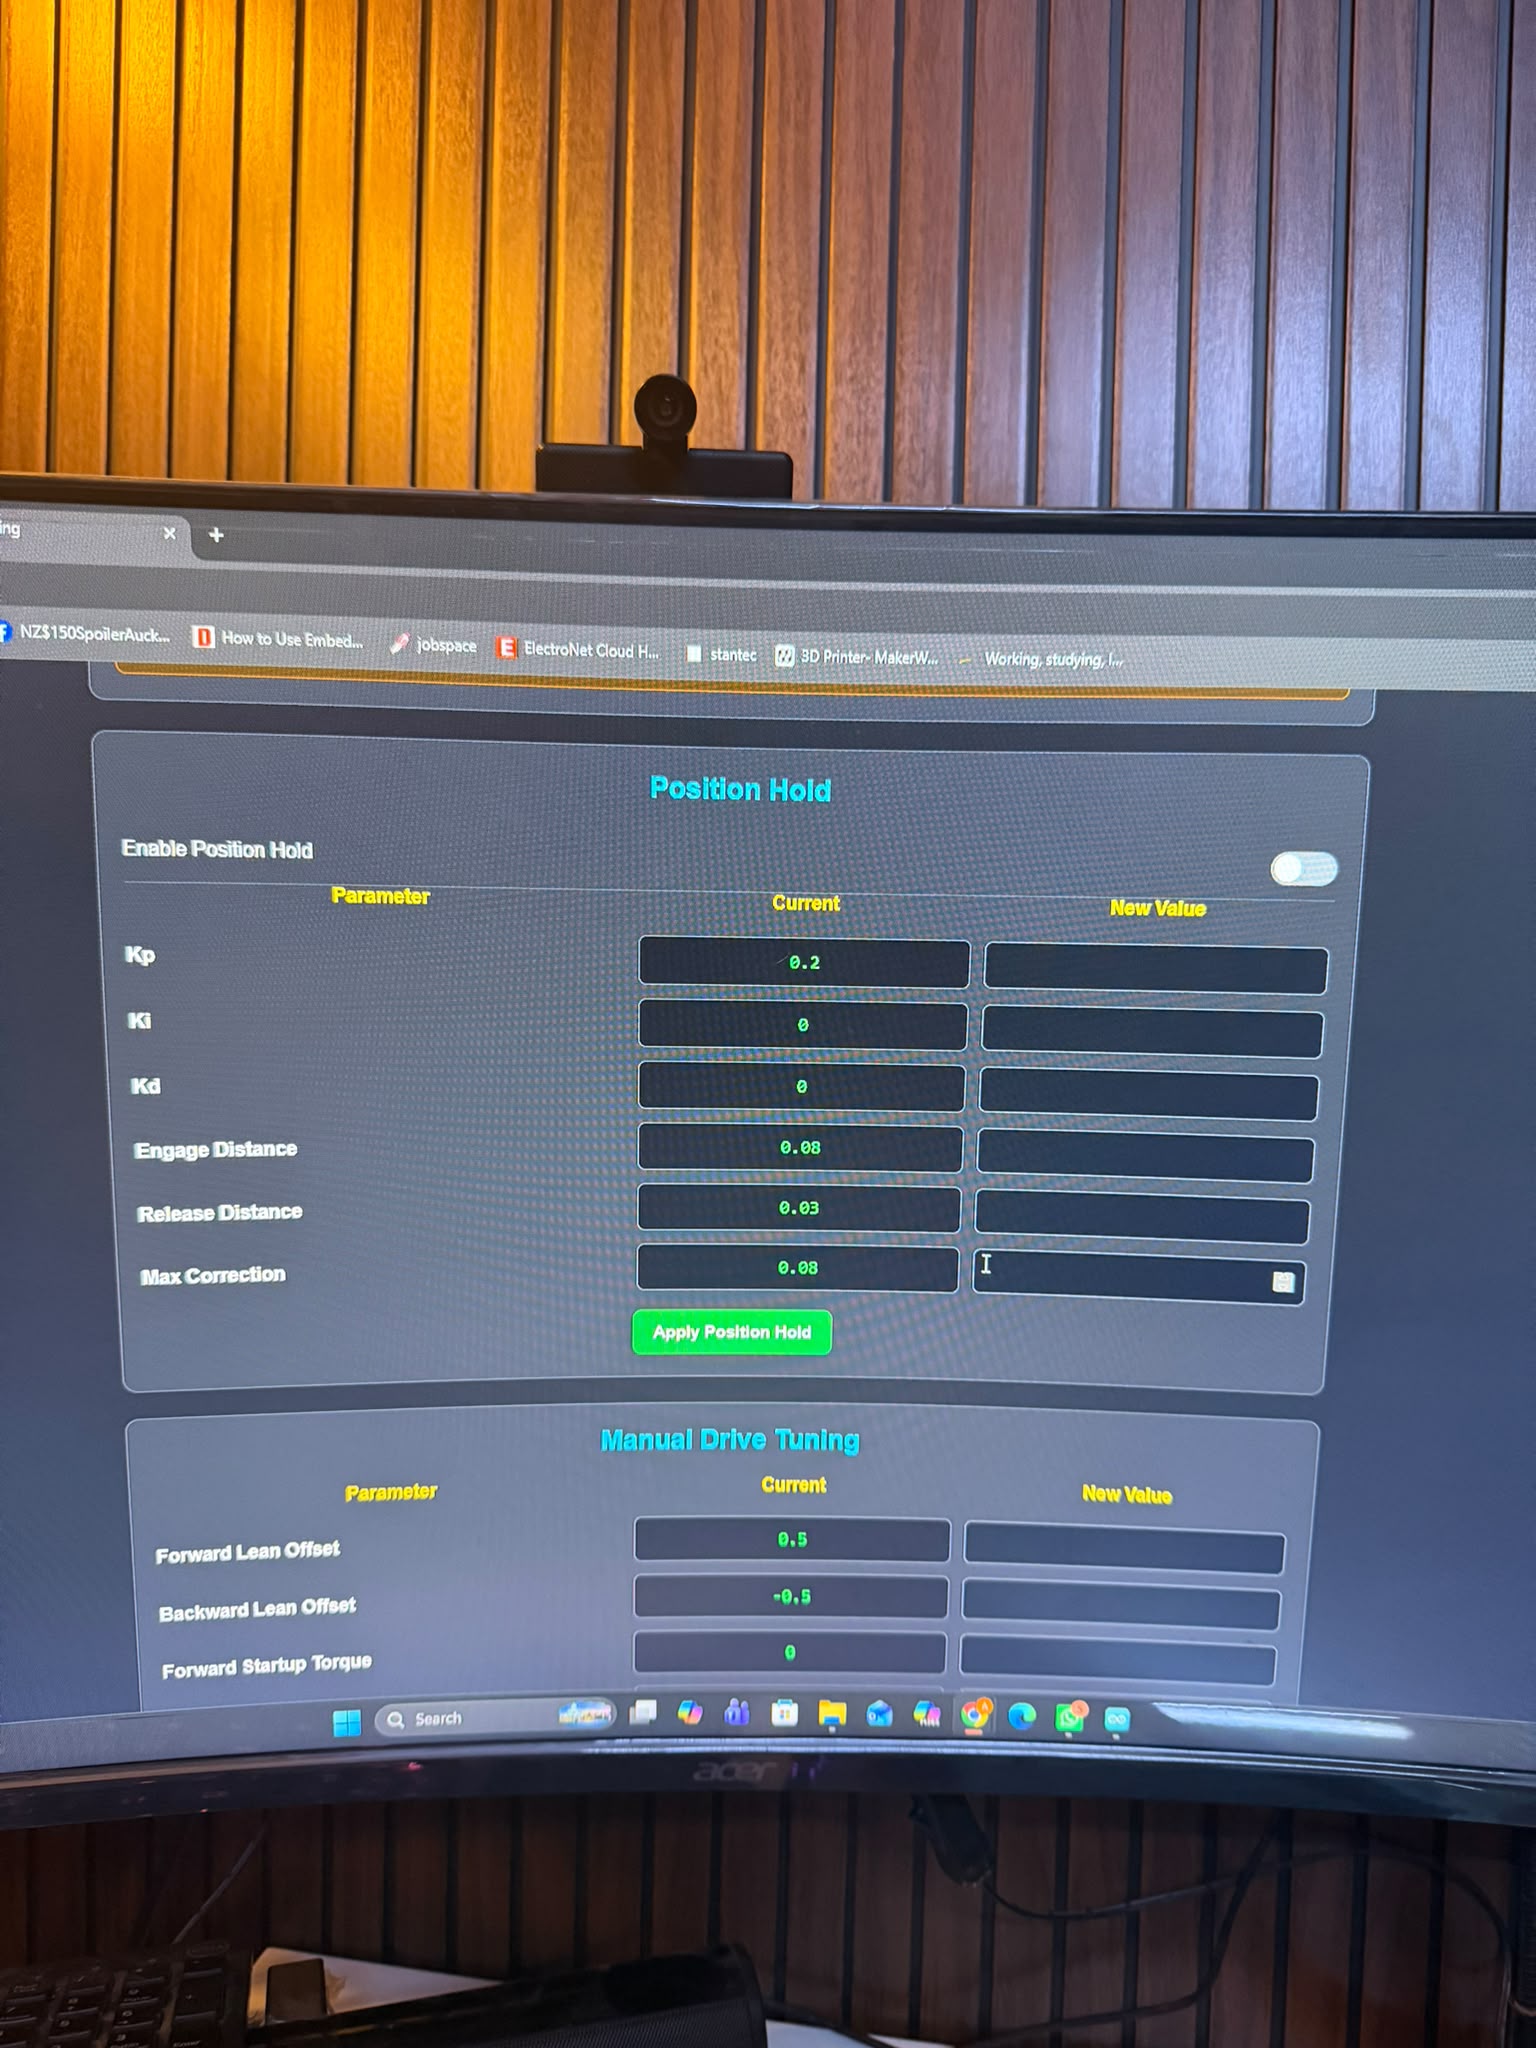
Browser-based interface was Developed to reduce repeated code uploads during Testing. It provides movement commands, system status, arming and disarming, balance-controller tuning, position-hold tuning and manual-drive adjustment.
Testing and debugging
Dashboard helps isolate faults between the ESP communication link, Arduino Mega, IMU and ODrive. Runtime tuning allows controller parameters to be adjusted while observing the Robot's response, making it easier to Diagnose oscillation, slow correction, excessive torque and position-hold instability.
ODriveBNO086Arduino MegaESP web interface
PID controlPosition holdTorque control